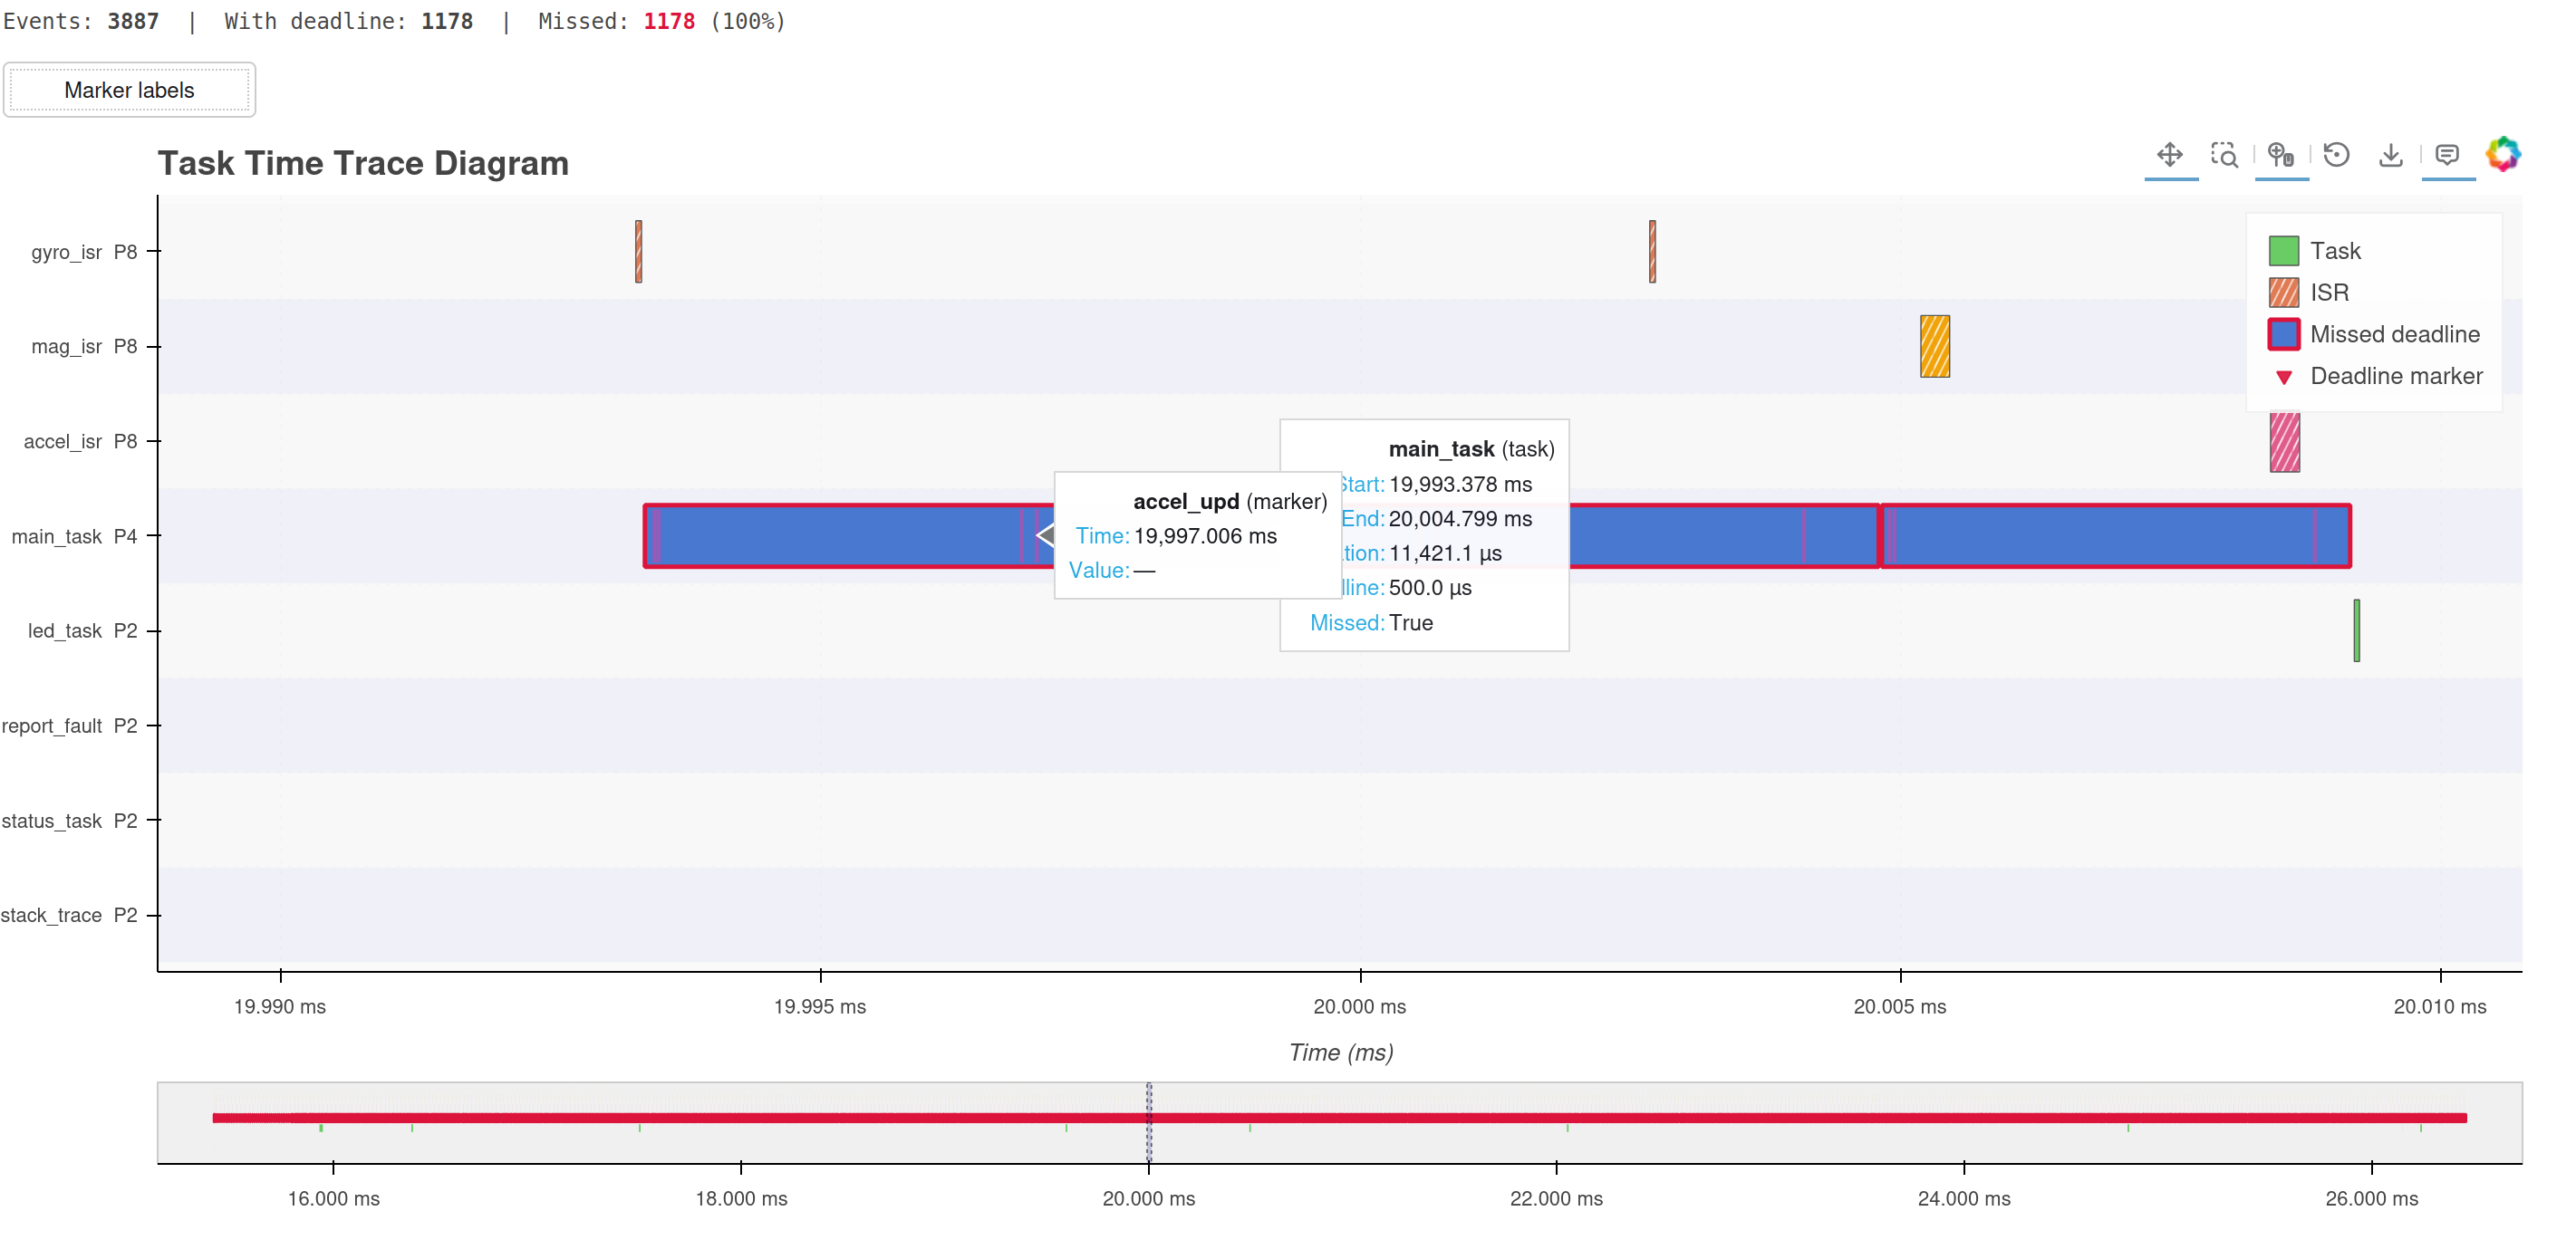
The graphical visualization and analysis tool is available in the companion Python package
embedded-etrace and can be easily installed.
Records named time spans (task activations, ISR executions) and point-in-time markers on bare-metal targets without a heap or OS.
Events are serialized as length-delimited protobuf frames that you forward over any byte transport — RTT, UART, USB, or a ring buffer for post-mortem analysis in the GUI.
TraceTransport is the low-level primitive: it receives a pre-constructed [TraceEvent] and
forwards it over your chosen transport. TraceSink is the recording layer built on top: it reads
the hardware clock and calls the record_* helpers.
Types that only move pre-built events (e.g., a downstream serialiser driven by a task queue)
implement TraceTransport alone. Types that also originate recordings implement both.
use execution_trace::{TraceTransport, TraceSink, TracingError, TraceEvent};

struct MyRttSink { /* ... */ }

impl TraceTransport for MyRttSink {
    fn write_event(&mut self, event: TraceEvent) -> Result<(), TracingError> {
        // encode and forward the event bytes over your chosen transport
        Ok(())
    }
}

impl TraceSink for MyRttSink {
    fn now_ticks(&self) -> u64 {
        0 // replace with your hardware timer
    }
}use execution_trace::{TraceSink, SourceType};
fn my_isr(sink: &mut impl TraceSink) {
// at priority 8, with a relative deadline of 10 ms from activation
sink.record_span_start("my_isr", SourceType::Isr, 8, Some(10.0)).ok();
// ... work ...
sink.record_span_end("my_isr").ok();
}
fn ukf_step(sink: &mut impl TraceSink) {
// with a payload of 3 (e.g., an iteration counter value or similar)
sink.record_marker("predict", Some(3)).ok();
// ...
}[TraceEncoder] holds the three pieces of per-stream state the wire format needs: the name
dictionary, the timestamp base the deltas are taken against, and the sequence counter that
lets the host detect dropped frames. Emit the stream header once, then encode events:
use execution_trace::{SourceType, TraceEncoder, TraceEvent};
use execution_trace::encode::MAX_TRACE_BURST_SIZE;

// `new()` reads timestamps as 64-bit nanoseconds. For a sink returning a raw
// core cycle counter use `TraceEncoder::with_cycle_counter(72_000_000)`: the
// encoder then extends the 32-bit counter itself, so reading it costs the
// caller one volatile load.
let mut enc = TraceEncoder::new();
let mut buf = [0u8; MAX_TRACE_BURST_SIZE];

// Once, at startup: declares the tick unit and the active source mask.
if let Ok(n) = enc.encode_trace_start(0, 0x1F, &mut buf) {
    let _ = &buf[..n];
}

let mut name = heapless::String::<32>::new();
name.push_str("my_task").unwrap();
let event = TraceEvent::SpanStart {
    timestamp_ns: 1_000,
    name,
    source_type: SourceType::Task,
    sequence: 0,
    priority: 4,
    relative_deadline_ms: None,
};
if let Ok(encoded) = enc.encode(&event, &mut buf) {
    if encoded.name_registry_full {
        // The dictionary is full: the event went out with the reserved "unknown"
        // id. Count it — the stream stays decodable, but this name is lost.
    }
    // forward buf[..encoded.len] over your transport (RTT, UART, USB, etc.)
    let _ = &buf[..encoded.len];
}
The first sight of a name writes two frames — the dictionary entry, then the event — which
is why the buffer is [encode::MAX_TRACE_BURST_SIZE] rather than one frame.
A frame is not self-contained: its name is a dictionary id and its timestamp is a delta against
the previous frame. [encode::decode_trace_frame] therefore returns a [RawTraceFrame], and the reader
resolves both from state it carries across the stream:
use execution_trace::{FrameKind, encode::decode_trace_frame};

// raw_bytes arrives from your transport (RTT, UART, file, etc.)
let (frame, consumed) = decode_trace_frame(raw_bytes).unwrap();

// A dictionary entry or the stream header carries an absolute timestamp and
// re-establishes the origin; every other frame is a delta against it.
clock = match frame.kind {
    FrameKind::NameRegistered | FrameKind::TraceStart => frame.timestamp_ticks,
    _ => clock + frame.timestamp_ticks,
};
if frame.kind == FrameKind::NameRegistered {
    names.insert(frame.name_id, frame.name);
}
examples/simulate.rs carries a complete worked reader; the execution-trace Python package
does the same job and renders a timing diagram from it.
Each frame is a standard protobuf length-delimited record:
[ varint: payload byte count ][ protobuf-encoded TraceFrame ]
One flat message carries every frame class, discriminated by its event_type: the three
per-occurrence events, the dictionary entry that assigns a name its id, and the stream header.
proto3 omits unset fields, so an event pays nothing for the dictionary fields it does not use.
A steady-state event costs 11-13 bytes — the name, the priority and the deadline are sent once per name rather than on every occurrence, and the timestamp is a delta.
Maximum frame size is [encode::MAX_TRACE_FRAME_SIZE] (128 bytes), and one encode call writes
at most [encode::MAX_TRACE_BURST_SIZE]. Name strings are capped at 32 bytes; longer names cause
record_* to return [TracingError::MessageDropped] before sending. The dictionary holds
[encode::NAME_REGISTRY_CAPACITY] distinct names, after which events fall back to a reserved
"unknown" id rather than to a wrong decode.
The companion Python package embedded-etrace decodes the binary stream, matches span start/end pairs,
and renders a zoomable Bokeh timing diagram as a standalone HTML file. The intermediate format is
a CSV with columns name, type, start_us, end_us, priority, deadline_us, and value.
The examples/ directory contains a self-contained simulation that demonstrates the full
workflow without any hardware:
# 1. Install the Python package with diagram support
pip install embedded-etrace[diagram]

# 2. Simulate an embedded trace and write it to trace.bin
cargo run --example simulate --features std

# 3. Decode the binary trace and render an interactive HTML timing diagram
python examples/visualize.py
simulate records two control-loop iterations — a gyro_isr (ISR, priority 8) and a
control_task (task, priority 4) with ukf_predict/ukf_update markers — where the
first iteration meets its deadline and the second misses it. visualize.py reads
trace.bin, writes a temporary CSV, and produces diagram.html that you can open in any
browser.
Both scripts accept --help for available options (e.g. --input, --output, --title
for visualize.py).
The crate is no_std by default. Enable the std feature for tests:
[dev-dependencies]
execution-trace = { version = "0.1", features = ["std"] }The enabled feature (on by default) gates the entire implementation. When you disable it, every
TraceSink method becomes a zero-cost no-op and the compiler eliminates every call site — no
overhead in production builds, no #[cfg] guards in your application code.
# your crate's Cargo.toml
[features]
trace = ["execution-trace/enabled"]

[dependencies]
execution-trace = { version = "0.1", default-features = false }
Then pass --features trace (or your own feature name) to enable tracing for a specific build:
cargo build --features traceYour call sites require no changes: record_span_start, record_span_end, and record_marker
are always present on TraceSink regardless of the feature flag — they just compile away when
enabled is off.